Peak power
Set by the laser.
dToF dev kits
LCM-based dToF lidar for outdoor robots, vehicles, and infrastructure.
Segmented VCSEL lidar fixes peak power, scan angles, and beam width together. LCM sets each on its own.
Set by the laser.
Set by LCM step size, in software.
Controlled by LCM, per scan.
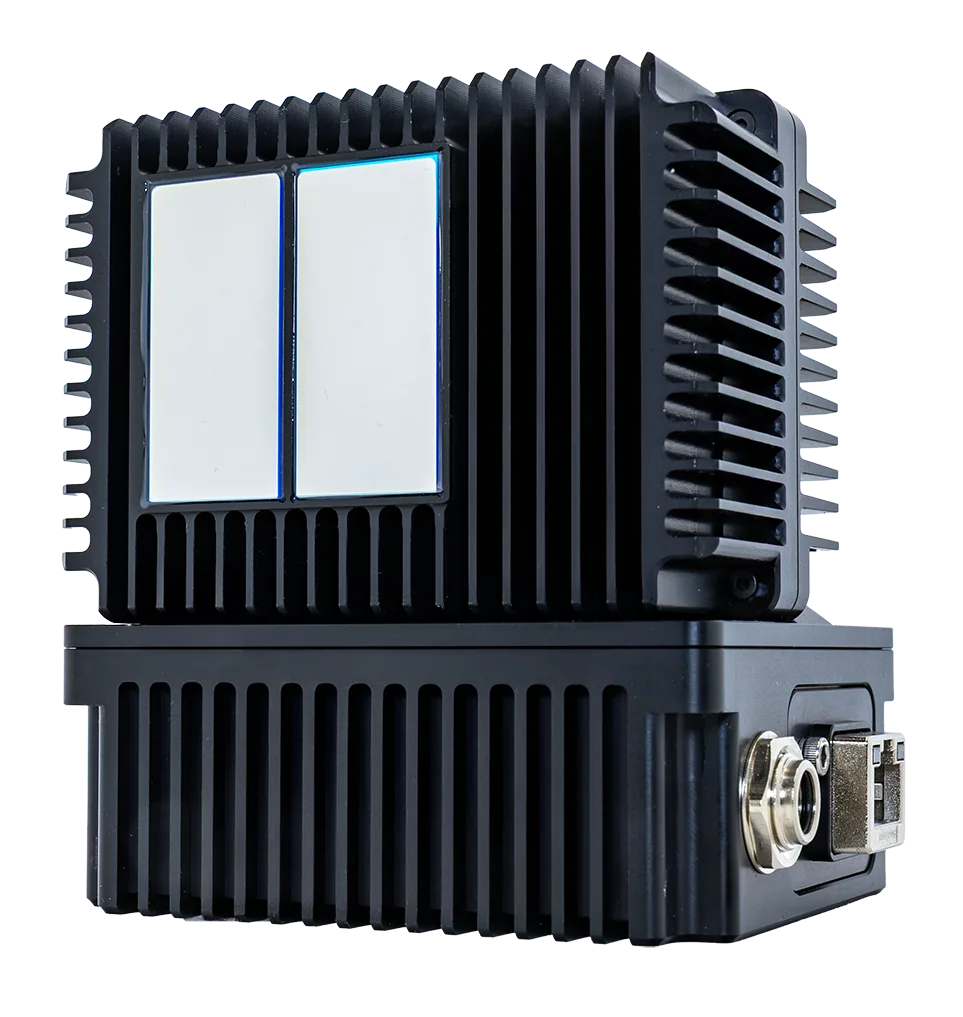
NM120
Solid-state dToF lidar for outdoor robots, vehicles, and infrastructure.
72 m, with 32 m to a 10% target.
ROIs at up to 900 Hz.
Bright and dark targets in one scan.
New capabilities, such as HDR, near-range accuracy, and interference reduction, arrive as software updates.
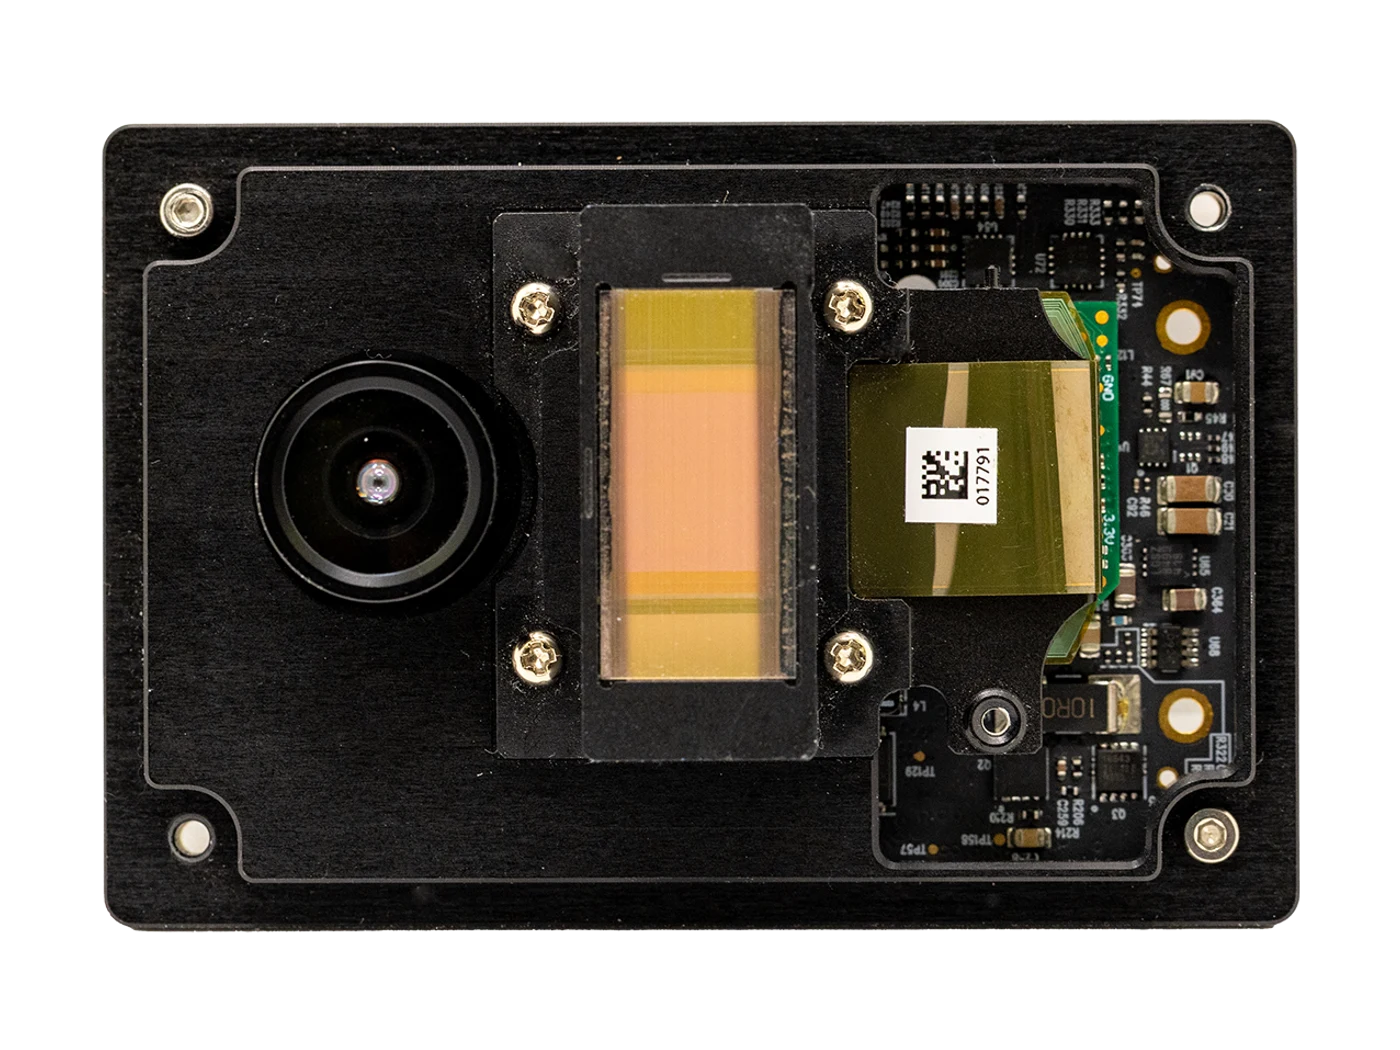
Use NM120 as a complete lidar, or take it apart. The sensor head outputs MIPI, so you can pair it with your own compute and embed it directly in your platform or a custom enclosure.
Sensor head plus compute, GigE out.
Sensor head only, MIPI out.
Embed the internals in your platform.
A low-power pulse runs in the same scan as the main pulse. Retroreflectors no longer blind the sensor, and people nearby keep sharp outlines.
NM120 tracks a basketball dribble at 80 fps, narrowing its field of view from 90° to 10° in software.
Integrates with your stack: API with ROS and custom frameworks; dynamic ROIs, virtual lidar, and line-scan modes.
Curb, sidewalk, and crossing navigation around people.
Near-field coverage around the vehicle.
People and obstacle detection around working machines.
Traffic, intersection, and parking monitoring.
Perimeter and area monitoring, day and night.
MD180
Built on our next-generation LS20 system-on-chip.
Tell us your environment, target range, and coverage needs. We will send the right datasheets and set up your evaluation.
Reference designs show what LCM enables. They are not optimized for size, cost, or qualification.