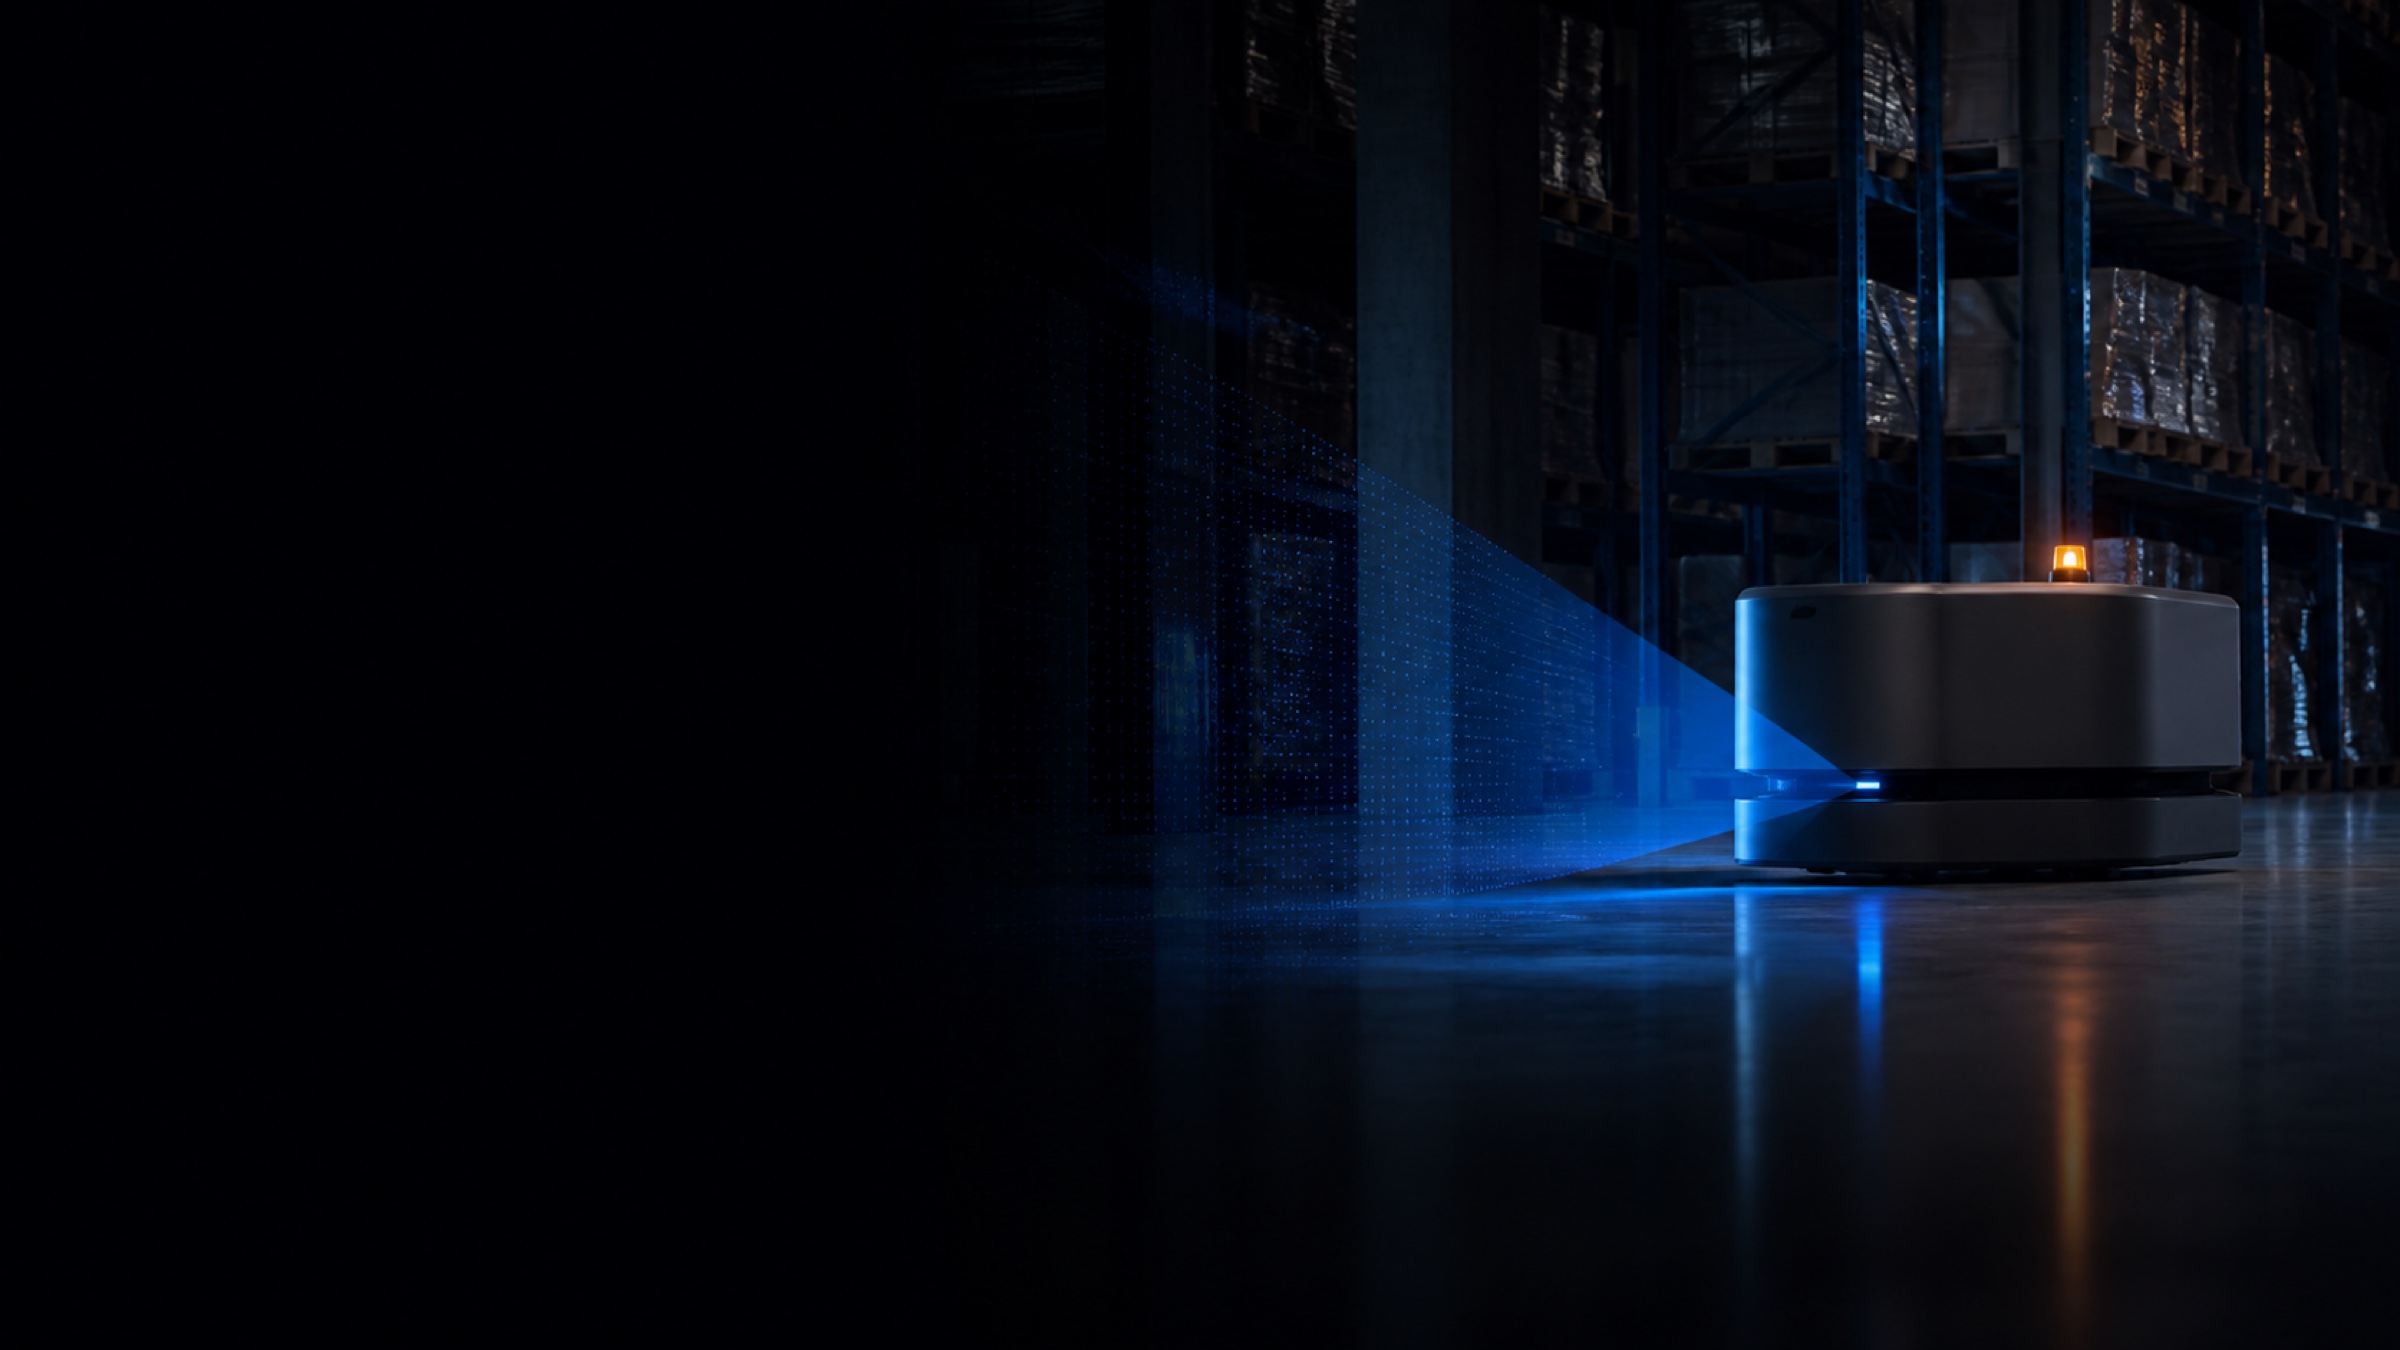
Fixed Field of View
Static FOV and scan patterns miss critical information.
Lumotive Sense
3D sensing for Physical AI. One sensor, multiple modes, adapted in software.
Conventional sensing systems struggle to deliver the performance, adaptability, and efficiency required for today's autonomous machines.
Static FOV and scan patterns miss critical information.
High system cost and complexity from stitching multiple sensors.
Poor performance in complex and dynamic environments.
Limited flexibility across use cases and operating conditions.
The answer
Each problem above, solved in software, by one sensor.
Your perception system decides where to look. LCM puts the light there, in microseconds.
One wide-FOV sensor replaces several fixed ones.
Reduced multipath and saturation give your perception models better point clouds to train and run on.
Laser power goes where it is needed, extending range.
Focus on people, obstacles, or pallets, and change focus in software.
Fewer sensors and targeted illumination reduce system cost and power budget.
Solid-state design means fewer failure points and less maintenance.
The result: robots and vehicles that do more work, with less downtime.
Sensing for robots and vehicles
Robots and vehicles need to see more, with fewer sensors, at lower cost and power. LCM-based 3D sensing gives perception teams control over where and how the sensor looks.
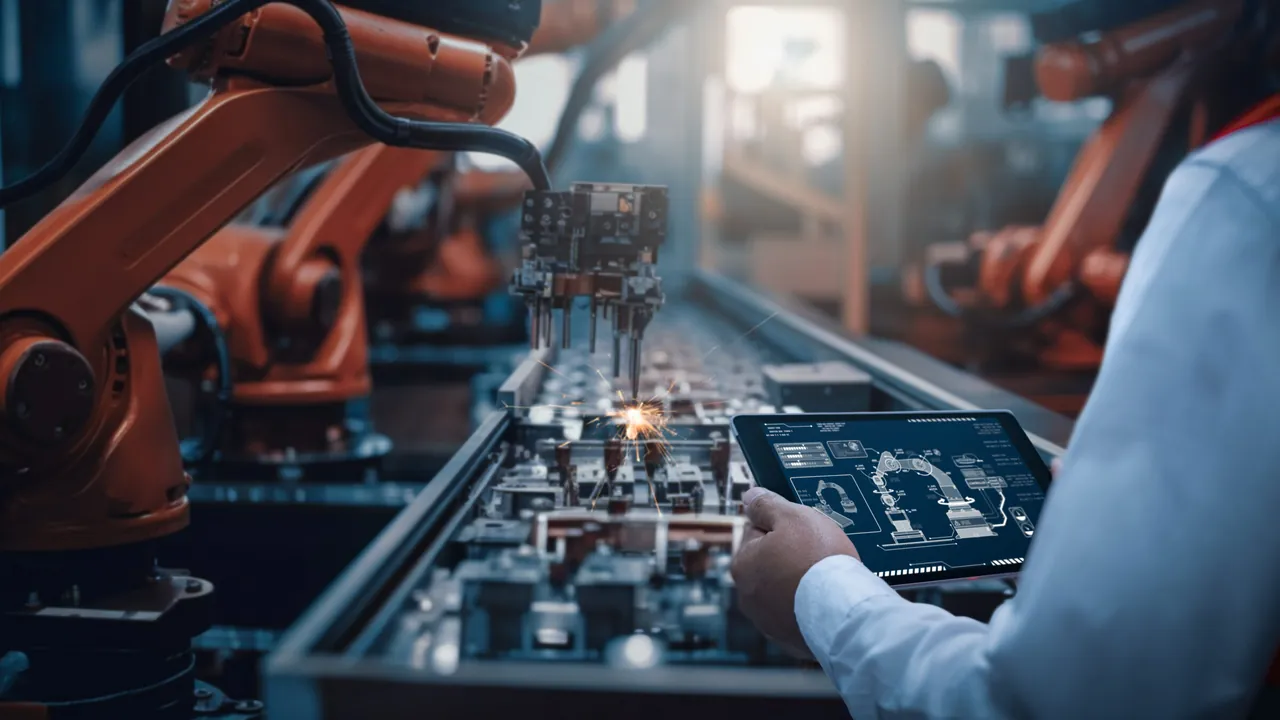
Indoor sensing · LCM-based iToF
For AMRs, humanoids, forklifts, drones, and industrial automation.
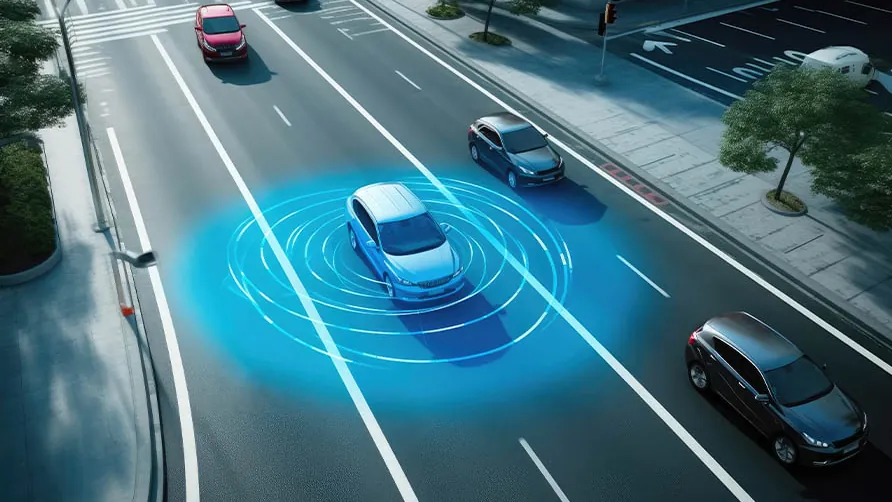
Outdoor and surround sensing · LCM-based dToF
For vehicles, heavy equipment, and outdoor robots.
Only possible with LCM
Retroreflectors and nearby bright objects saturate time-of-flight sensors and smear the scene around them.
LCM fires a low-power pulse in the same scan as the main pulse. Bright targets stay sharp, dark targets stay visible, and frame rate stays the same.
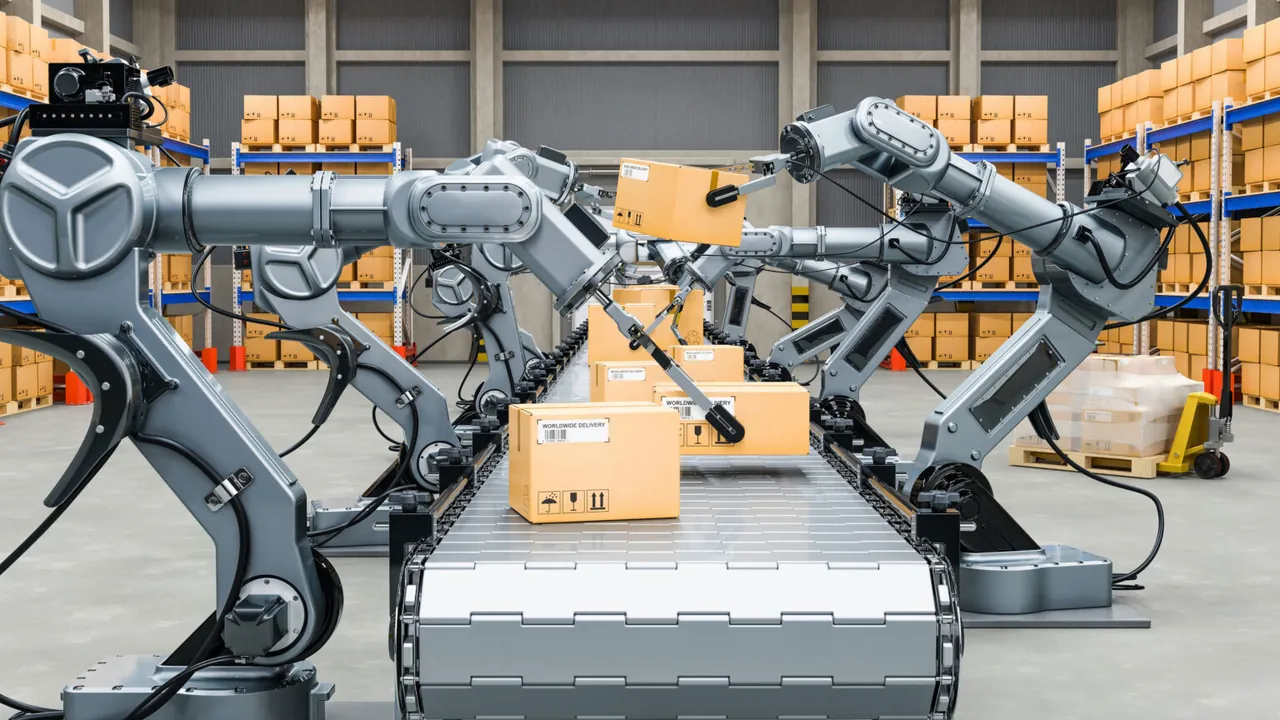
AMRs, humanoids, quadrupeds, forklifts, and industrial automation.
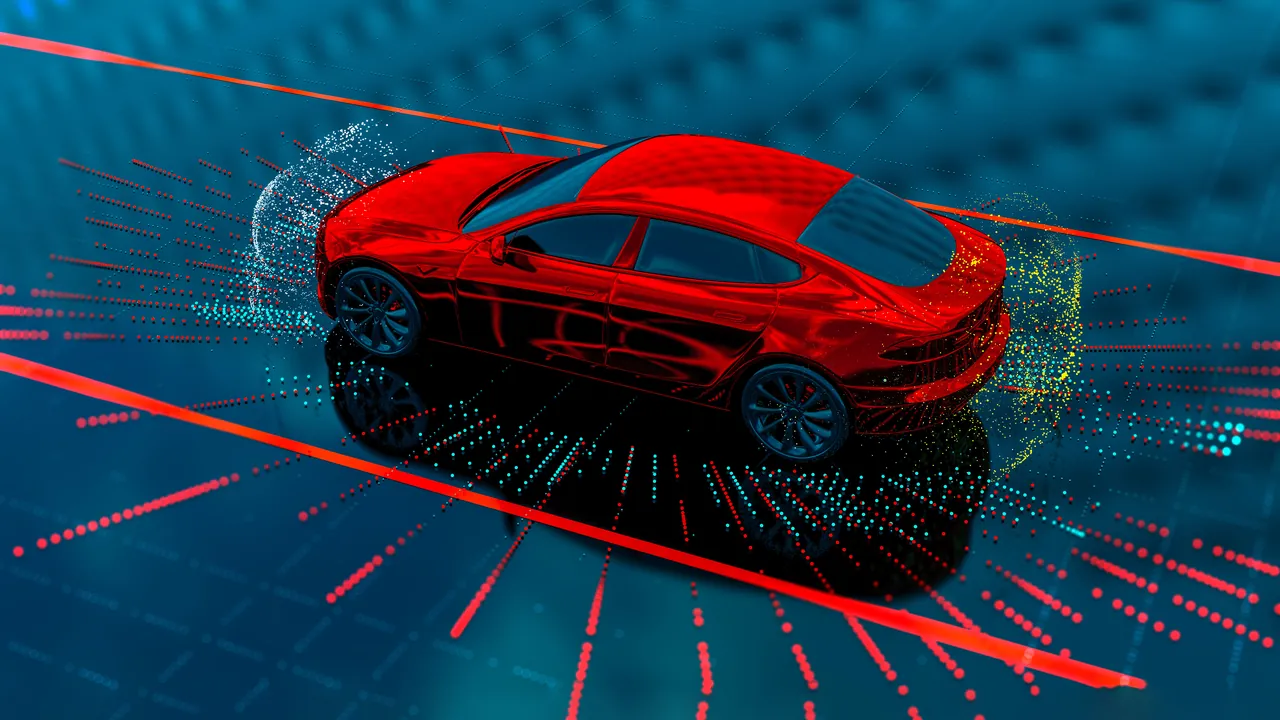
Surround sensing for passenger vehicles, robotaxis, trucking, and heavy equipment.
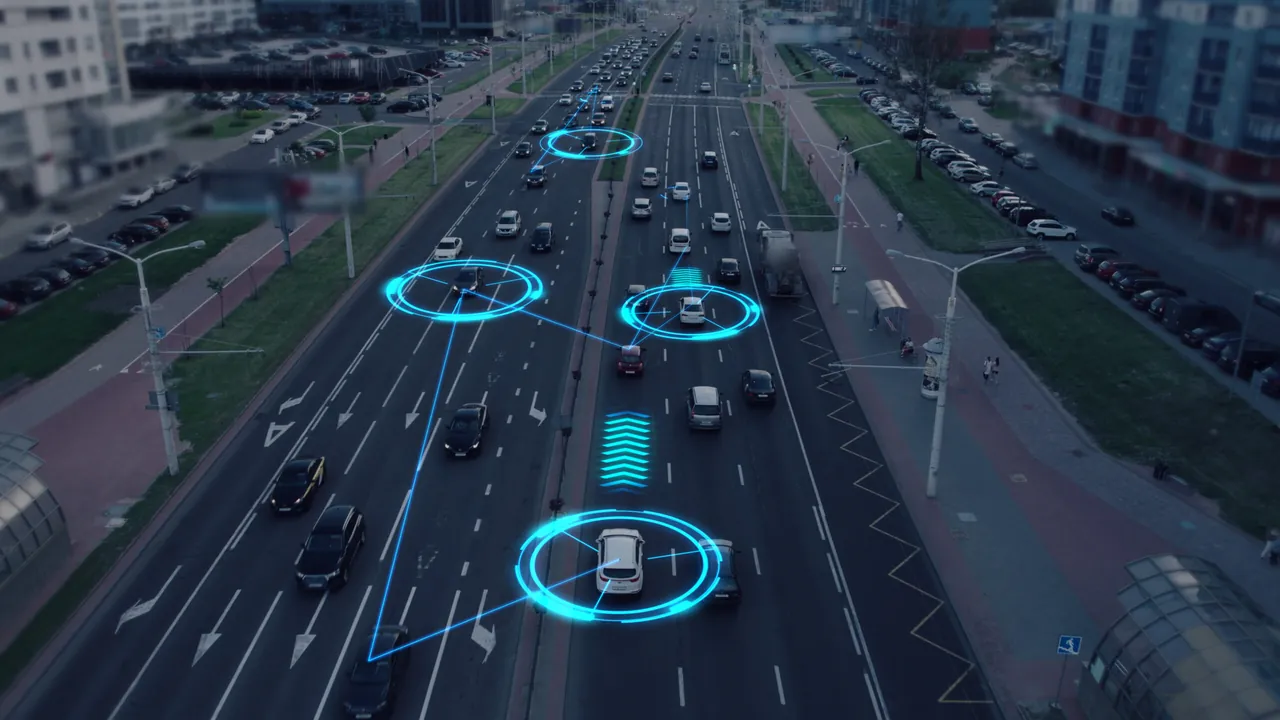
Traffic and parking monitoring, perimeter security, and privacy-aware people counting with depth data.
Start building
Add LCM beamforming to your own sensor design.
Long-range iToF depth, from embedded modules to RGB-D on Jetson.
Solid-state dToF lidar for indoor, outdoor, and surround sensing.

Tell us the specification you are designing to — field of view, range, form factor — and we will point you at the dev kit or reference design that gets you there fastest.